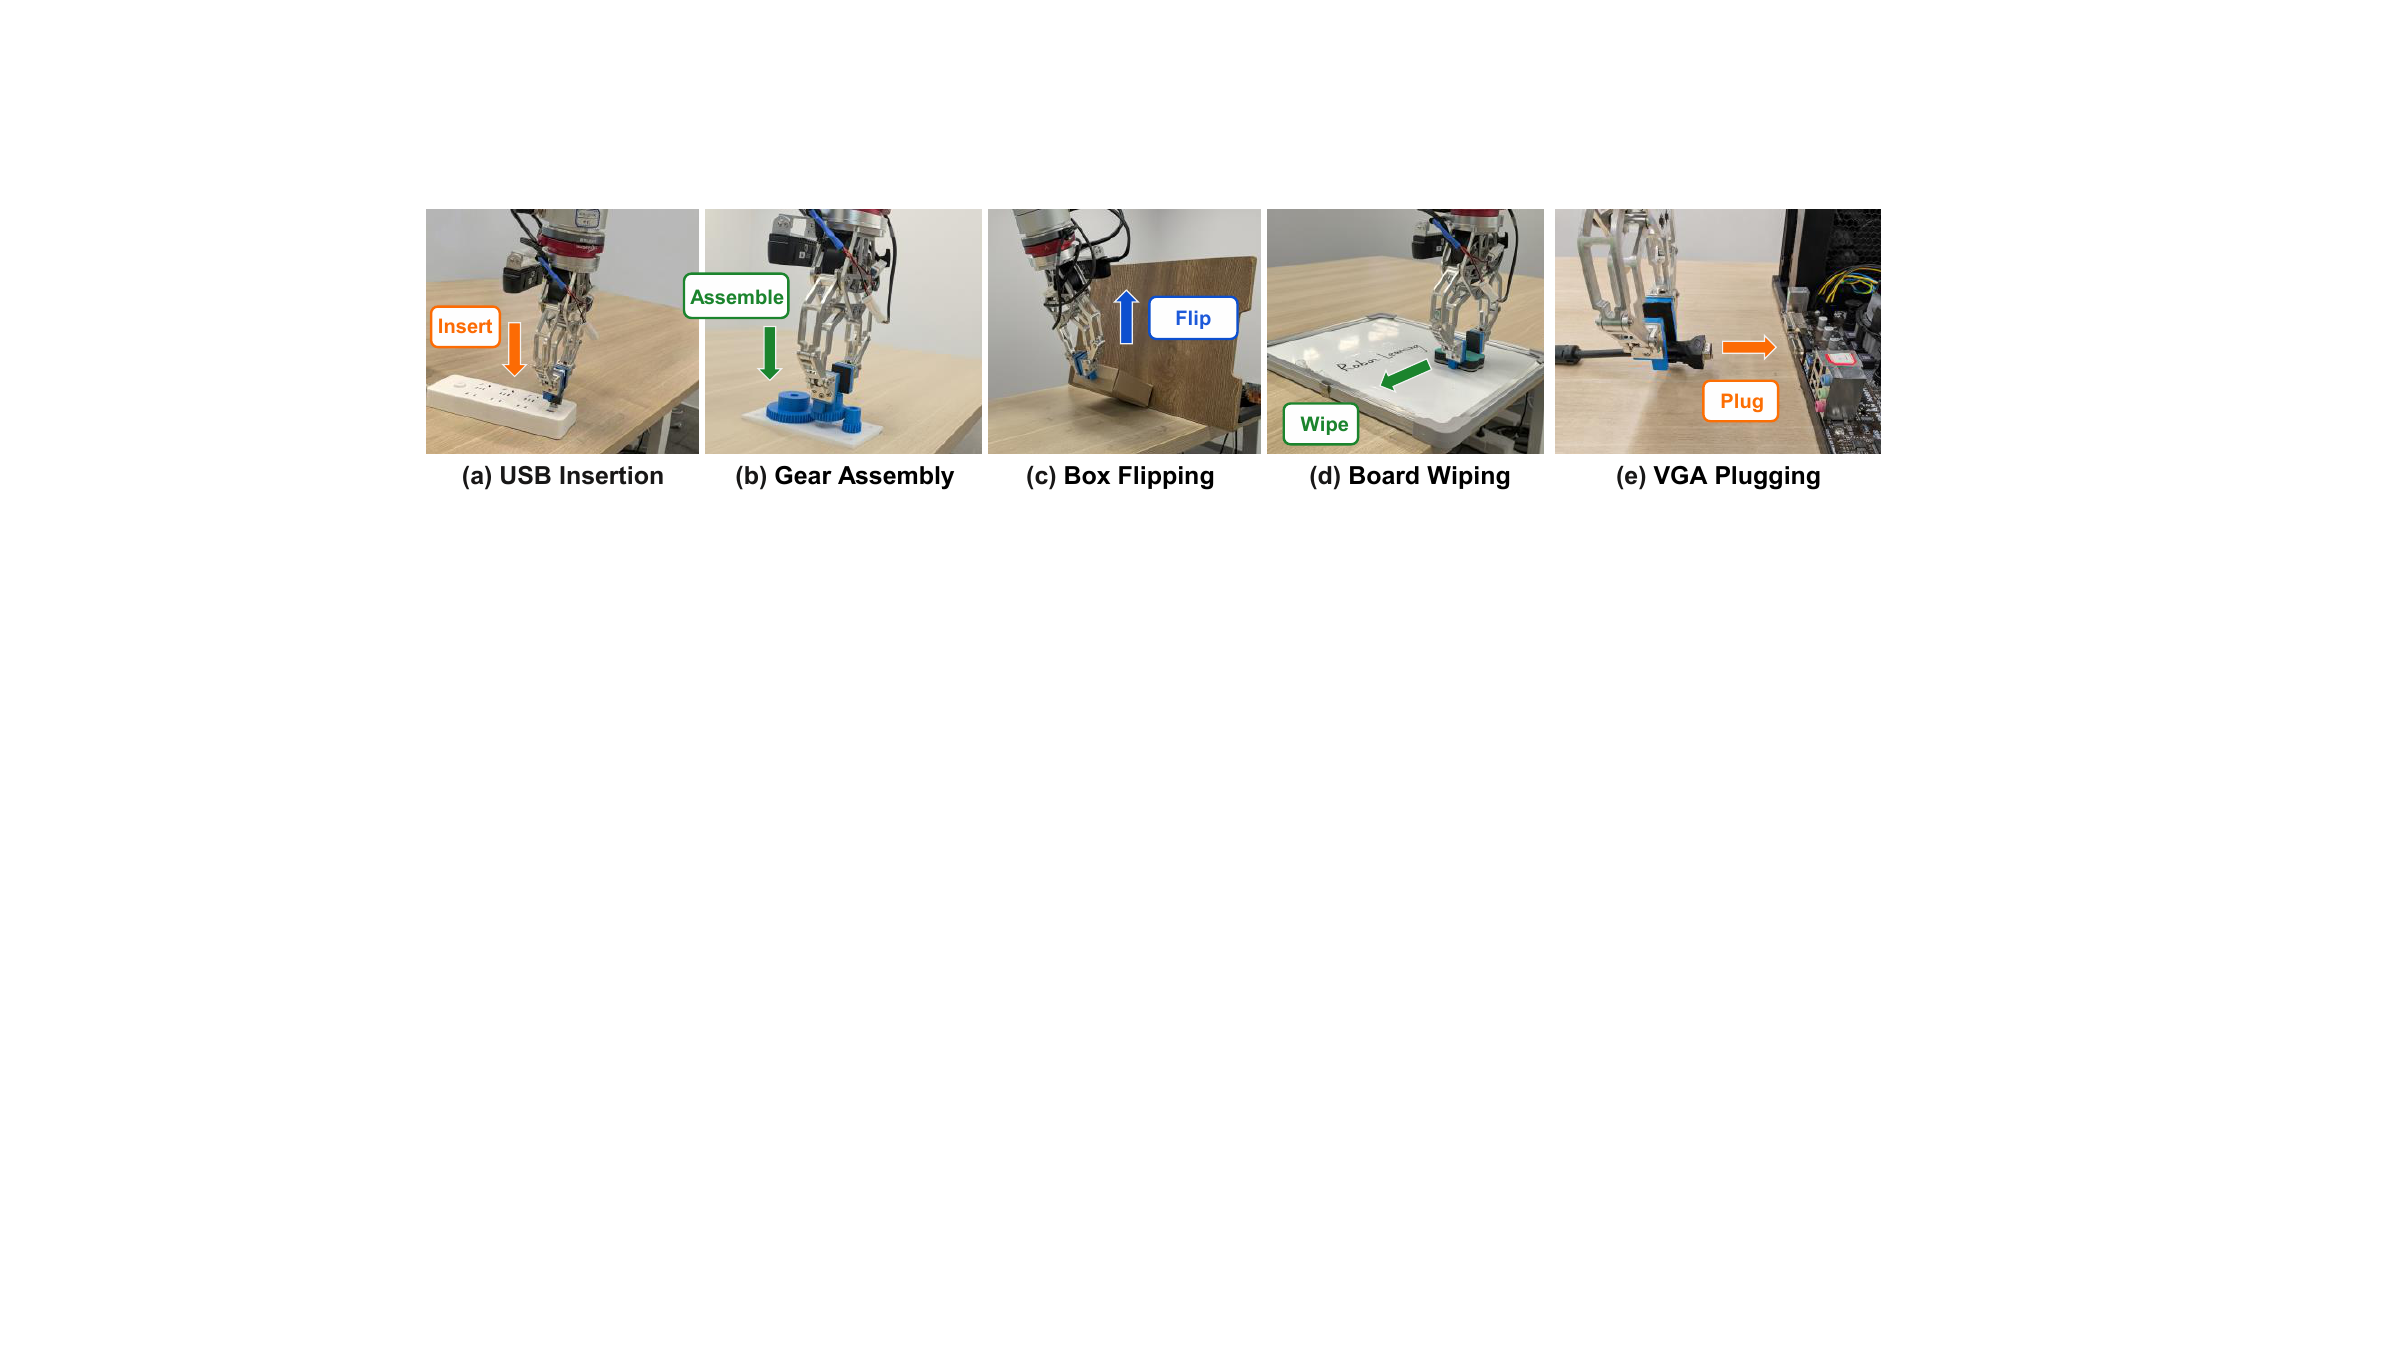
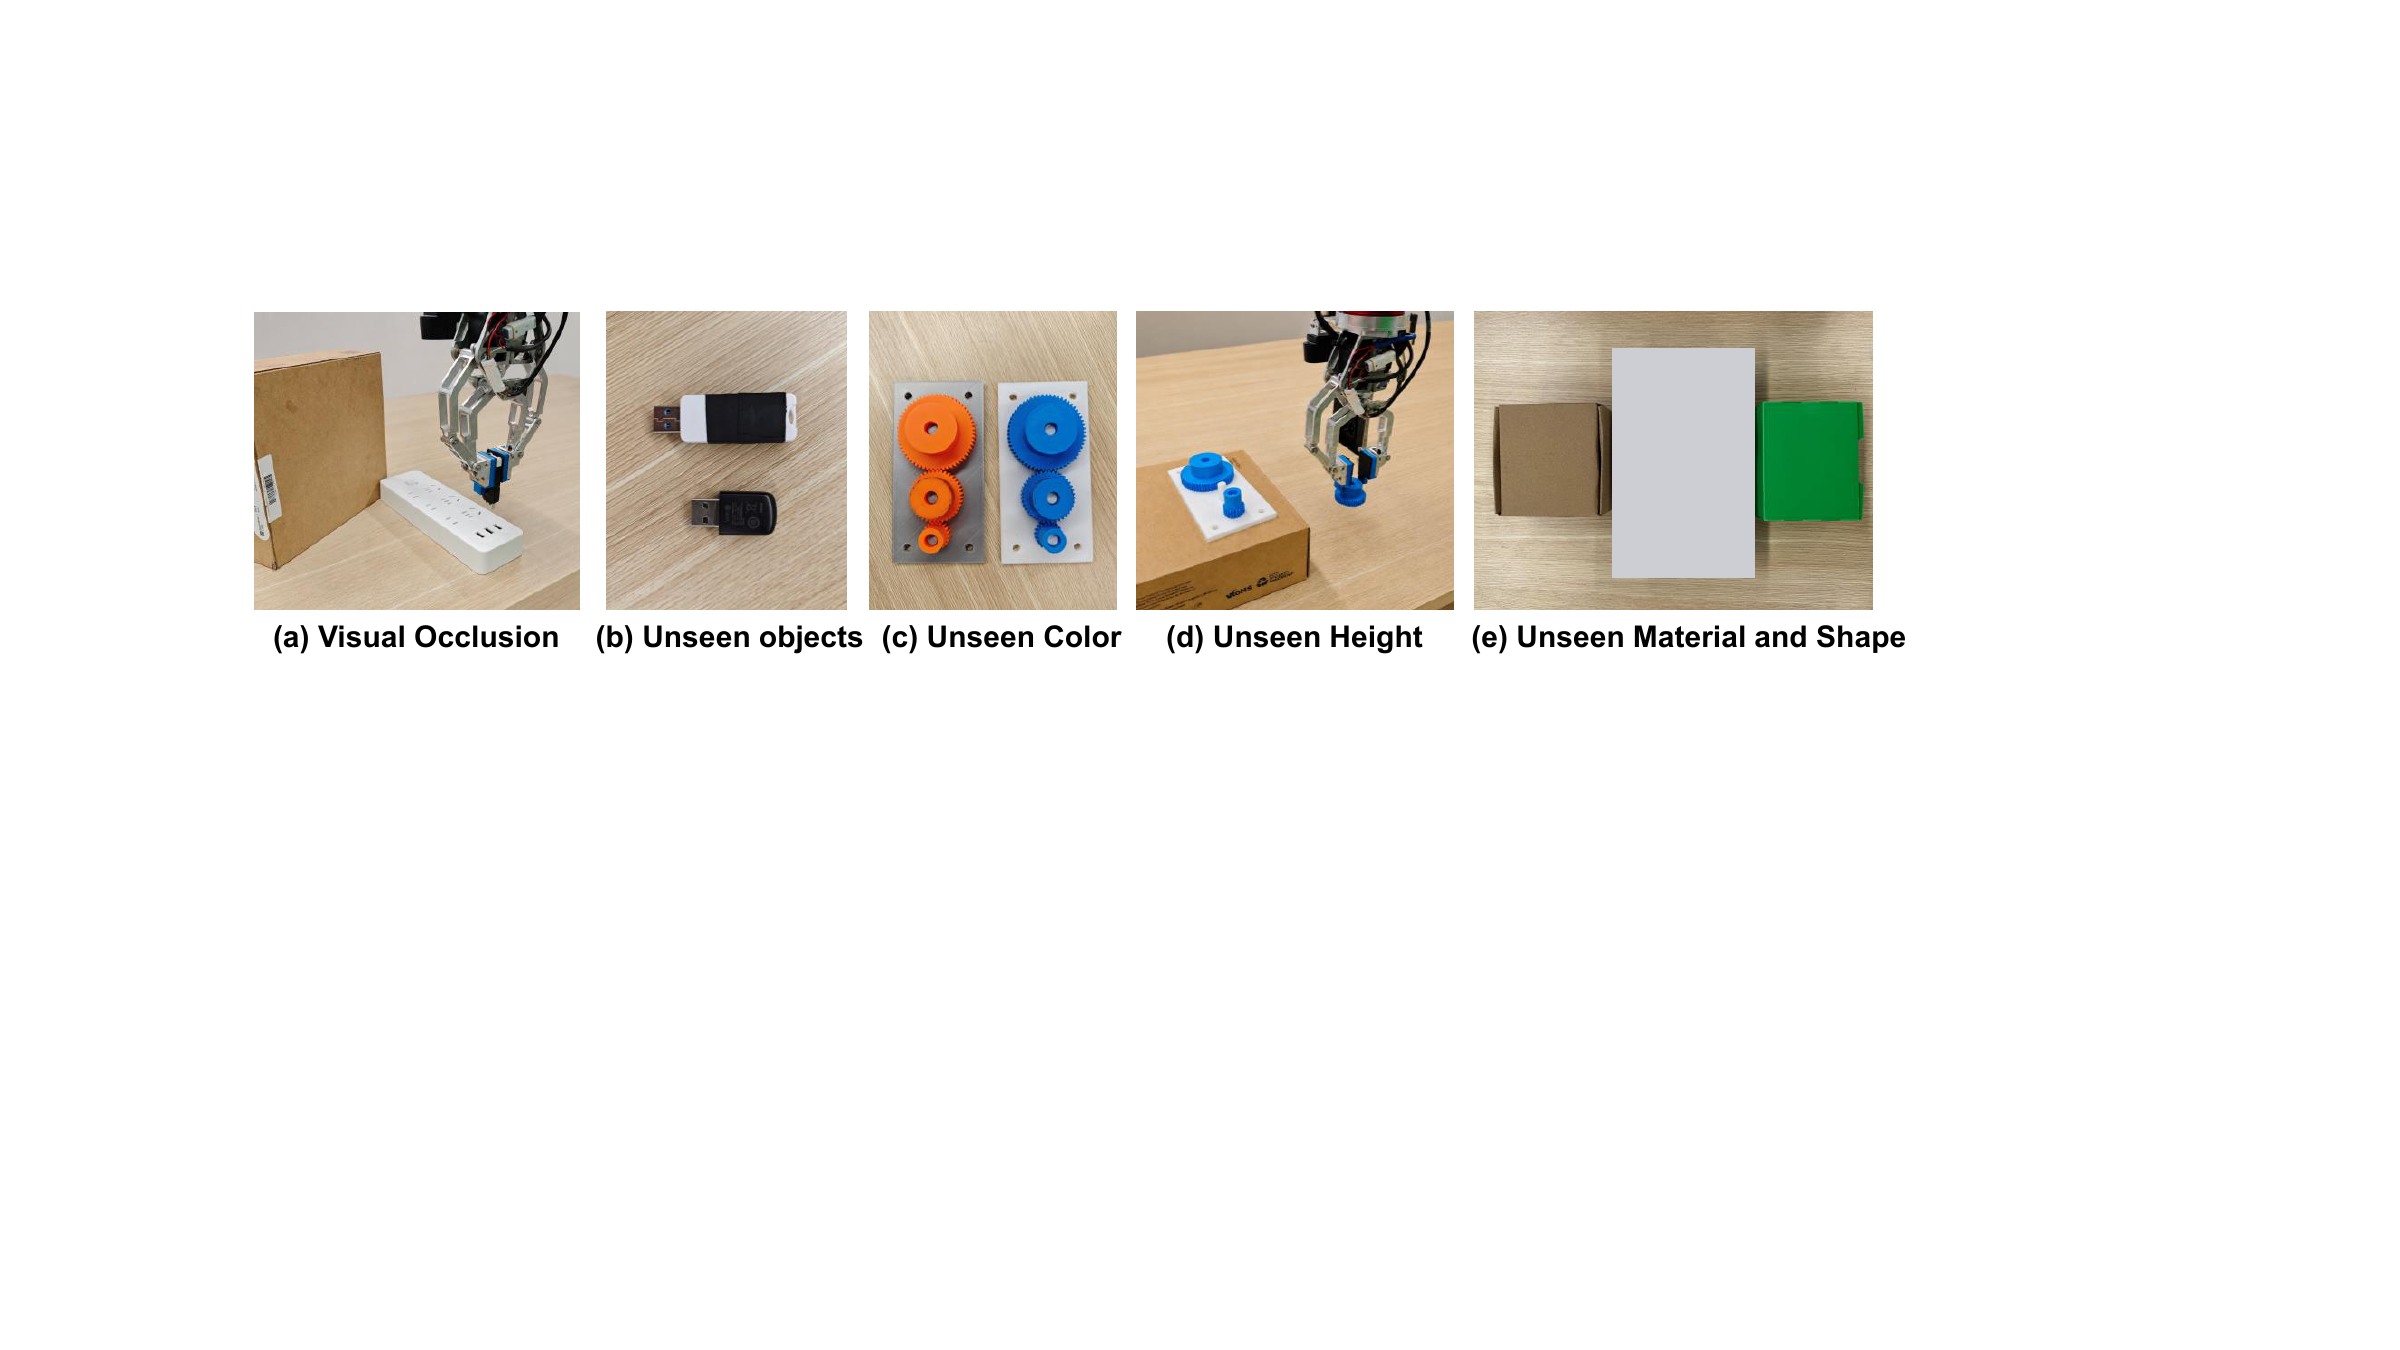
Motivation
Learning Latent Dynamics through Teacher–Student Distillation.
Adding force alone is not enough
When force is simply added as an input, rich visual cues can dominate the sparse force signals. The policy may still learn to copy demonstrated actions without understanding how contact will evolve, limiting its ability to handle new situations.
Predicting video can miss what matters for control
A realistic-looking video does not guarantee accurate contact dynamics. Predicting full frames also spends effort on backgrounds, appearance, and sensor noise. Adding force sensing to video models further requires substantial computation and synchronized training data.
Learn the motion and contact that matter
Optical flow directly describes how the robot and objects move, while force/torque signals reveal their contact interactions. Together, they capture complementary information for control. Action-guided distillation condenses these future signals into a compact representation, helping the policy learn what matters for choosing actions without reconstructing every sensory detail.

Figure 1. Comparison with prior methods.
(a) Force-aware VLAs incorporate force feedback but lack explicit modeling of future interaction dynamics. (b) Video-based WAMs model future dynamics through visual prediction, but often lack force/tactile feedback and may fit task-irrelevant visual details. (c) ForceLDM learns compact, action-relevant future dynamics by distilling future motion and force cues from a privileged teacher.